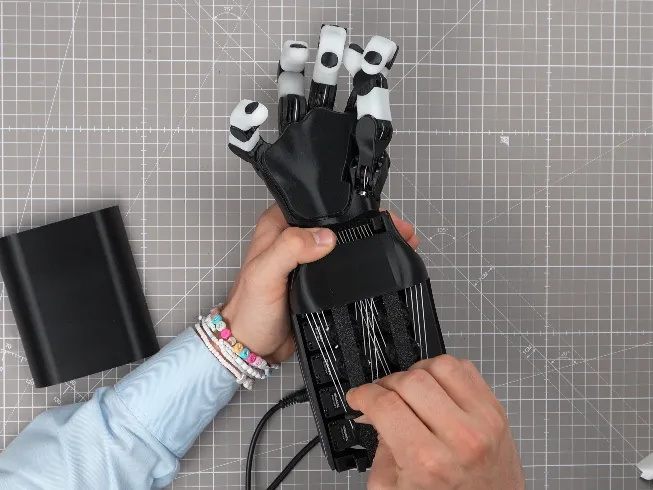
ORCA Hand 17-DOF Tendon-Driven Robotic Hand 作者:ORCA Dexterity, Inc. (originally ETH Zurich Soft Robotics Lab) · 示例作品 · 7 次浏览 · 0 次改作 A printable, human-sized dexterous hand whose 16 finger servos pull fishing-line tendons from a forearm tower 0保存改作复制链接 零件费用估算 14 个零件中有 6 个有价格难度困难制作时间Under 8 hours of assembly (paper)零件14 个零件 · 141 件 开始组装指南 →