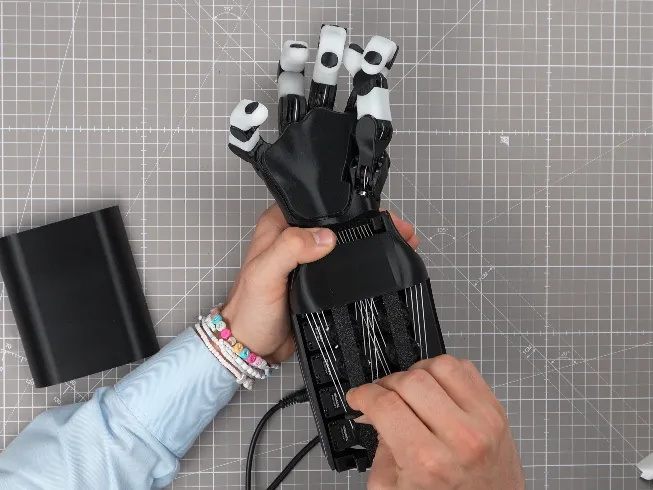
ORCA Hand 17-DOF Tendon-Driven Robotic Hand ORCA Dexterity, Inc. (originally ETH Zurich Soft Robotics Lab) 작성 · 예시 빌드 · 조회 7회 · 리믹스 0개 A printable, human-sized dexterous hand whose 16 finger servos pull fishing-line tendons from a forearm tower 0저장리믹스링크 복사 예상 부품 비용 부품 14개 중 6개 가격 있음난이도어려움제작 시간Under 8 hours of assembly (paper)부품부품 14개 · 141개 조립 가이드 시작 →