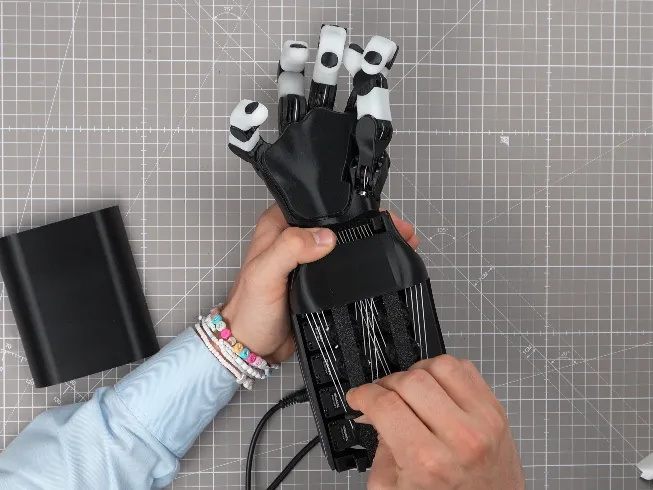
ORCA Hand 17-DOF Tendon-Driven Robotic Hand 作成:ORCA Dexterity, Inc. (originally ETH Zurich Soft Robotics Lab) · サンプル作品 · 7 回表示 · 0 件のリミックス A printable, human-sized dexterous hand whose 16 finger servos pull fishing-line tendons from a forearm tower 0保存リミックスリンクをコピー 部品代の目安 14 点中 6 点に価格あり難易度上級製作時間Under 8 hours of assembly (paper)部品14 点の部品 · 141 個 組み立てガイドを始める →