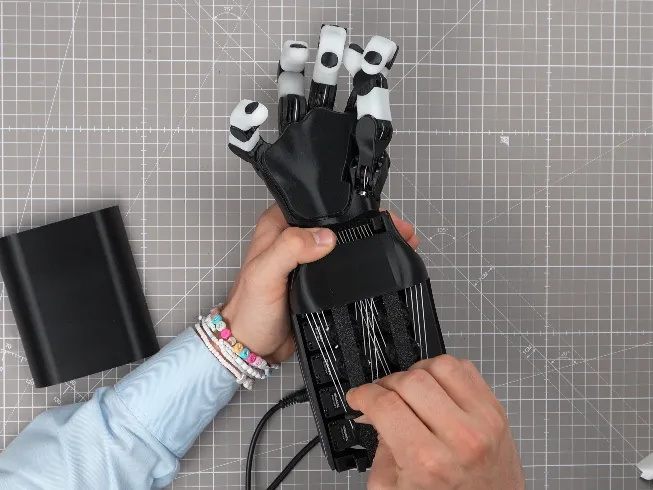
ORCA Hand 17-DOF Tendon-Driven Robotic Hand
Par ORCA Dexterity, Inc. (originally ETH Zurich Soft Robotics Lab) · Exemple de build · 7 vues · 0 remix
A printable, human-sized dexterous hand whose 16 finger servos pull fishing-line tendons from a forearm tower
0EnregistrerRemixerCopier le lien
Coût estimé des pièces
6 pièces sur 14 avec un prix
Difficulté
Difficile
Temps de réalisation
Under 8 hours of assembly (paper)
Pièces
14 pièces · 141 pcs