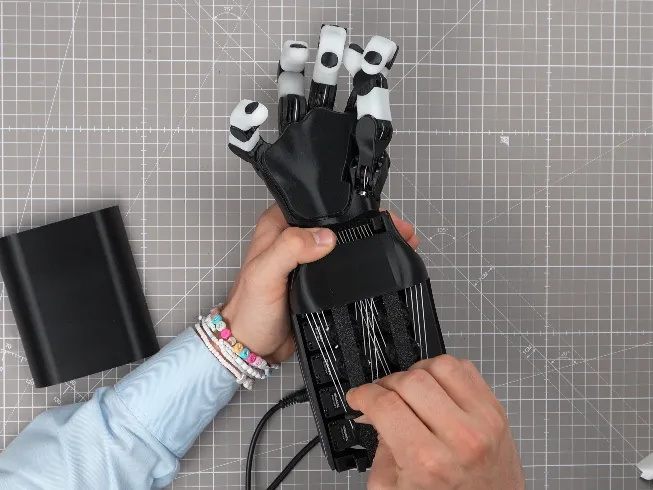
ORCA Hand 17-DOF Tendon-Driven Robotic Hand By ORCA Dexterity, Inc. (originally ETH Zurich Soft Robotics Lab) · Example build · 7 views · 0 remixes A printable, human-sized dexterous hand whose 16 finger servos pull fishing-line tendons from a forearm tower 0SaveRemixCopy link Estimated parts cost 6 of 14 parts pricedDifficultyDifficultBuild timeUnder 8 hours of assembly (paper)Parts14 parts · 141 pcs Start the assembly guide →