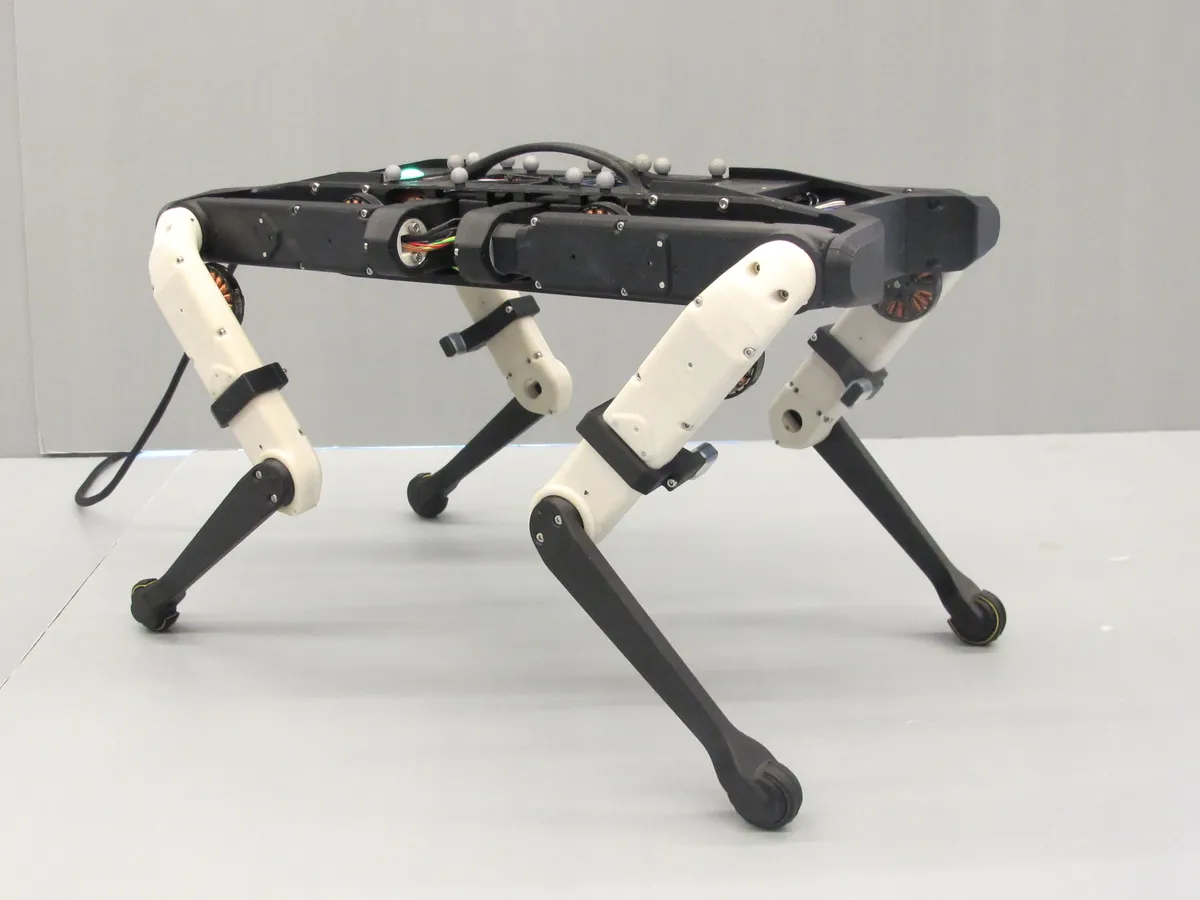
ODRI Solo-12 Torque-Controlled Quadruped 作者:Felix Grimminger and the Open Dynamic Robot Initiative (MPI-IS, NYU) · 示例作品 · 7 次浏览 · 0 次改作 The 12-joint version of the open ODRI research quadruped, with a hip ab/adduction actuator on every leg 0保存改作复制链接 零件费用估算还没有看到价格难度困难零件11 个零件 · 211 件 开始组装指南 →