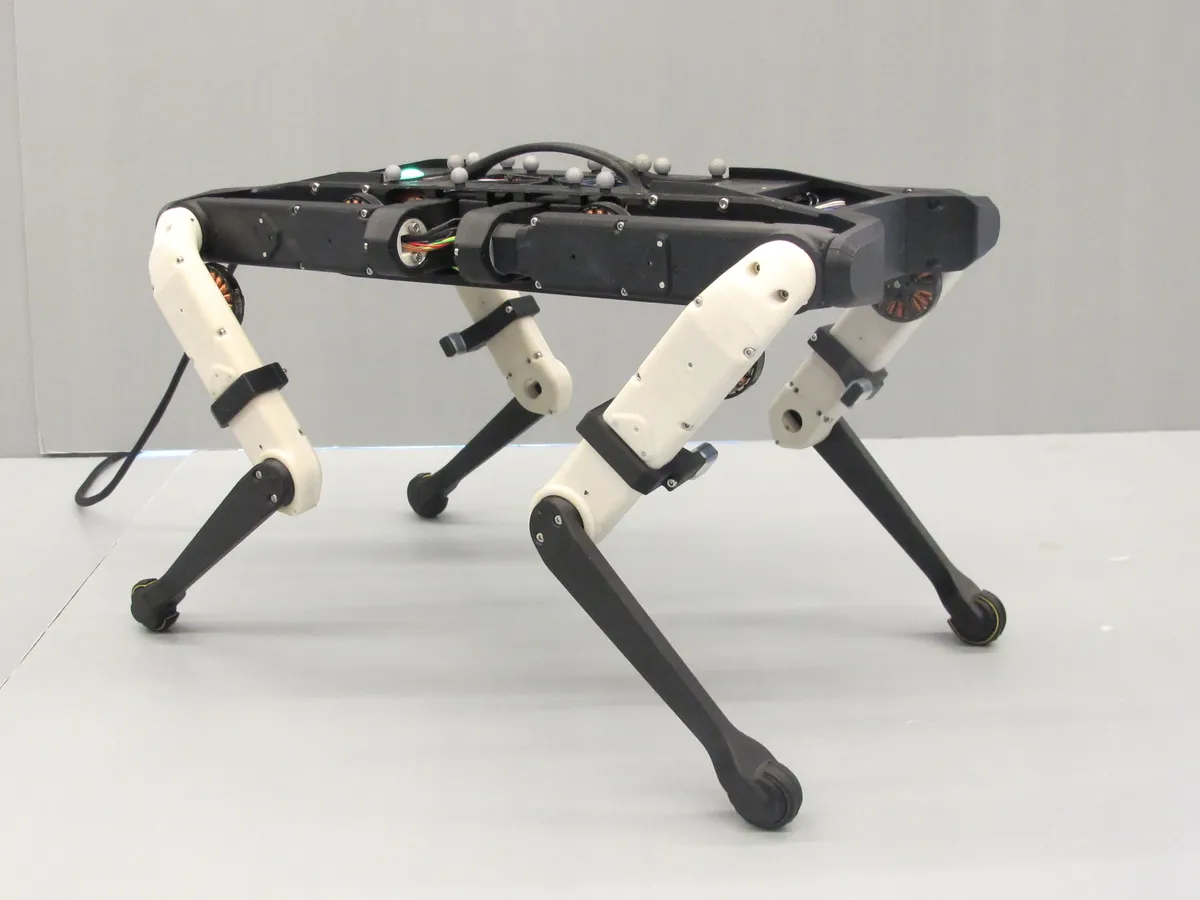
ODRI Solo-12 Torque-Controlled Quadruped Felix Grimminger and the Open Dynamic Robot Initiative (MPI-IS, NYU) 작성 · 예시 빌드 · 조회 7회 · 리믹스 0개 The 12-joint version of the open ODRI research quadruped, with a hip ab/adduction actuator on every leg 0저장리믹스링크 복사 예상 부품 비용아직 기록된 가격 없음난이도어려움부품부품 11개 · 211개 조립 가이드 시작 →