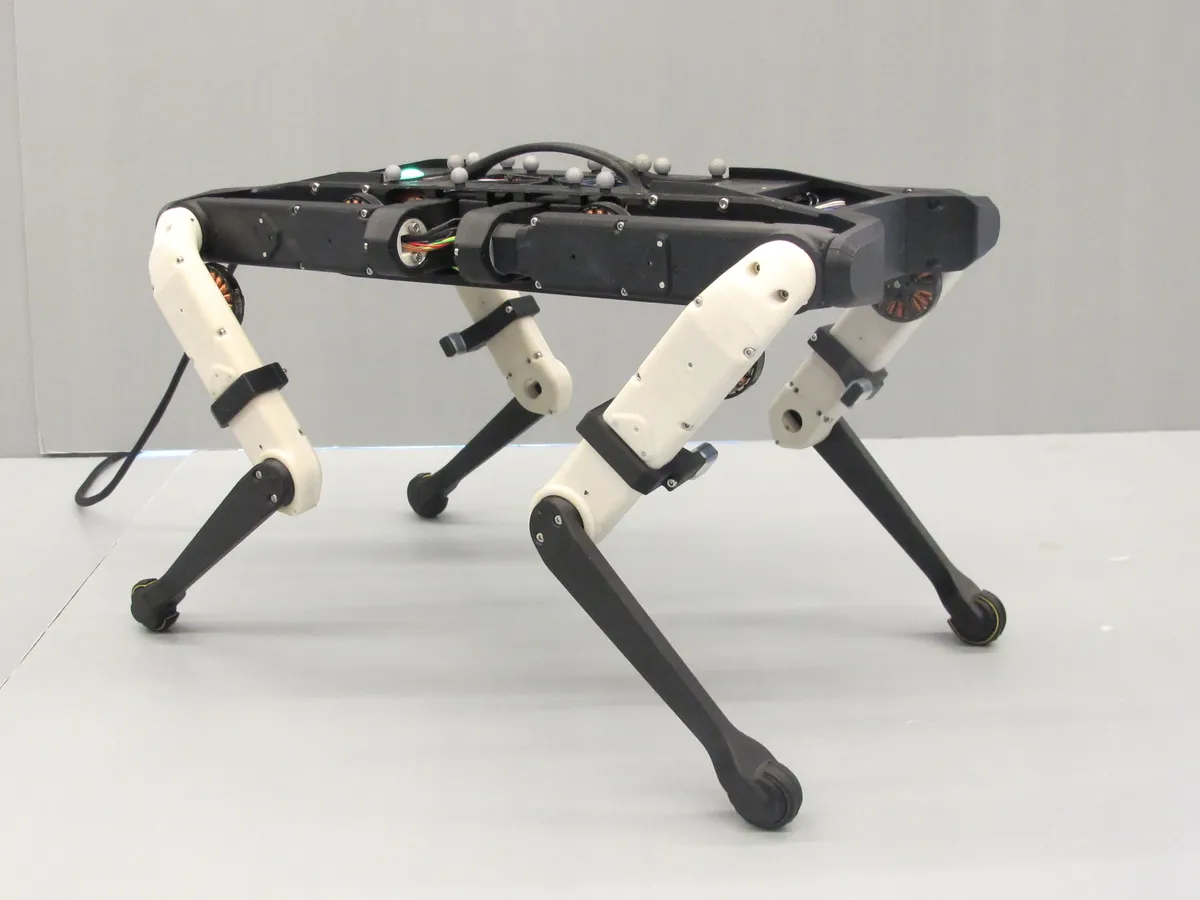
ODRI Solo-12 Torque-Controlled Quadruped 作成:Felix Grimminger and the Open Dynamic Robot Initiative (MPI-IS, NYU) · サンプル作品 · 7 回表示 · 0 件のリミックス The 12-joint version of the open ODRI research quadruped, with a hip ab/adduction actuator on every leg 0保存リミックスリンクをコピー 部品代の目安まだ価格の記録がありません難易度上級部品11 点の部品 · 211 個 組み立てガイドを始める →