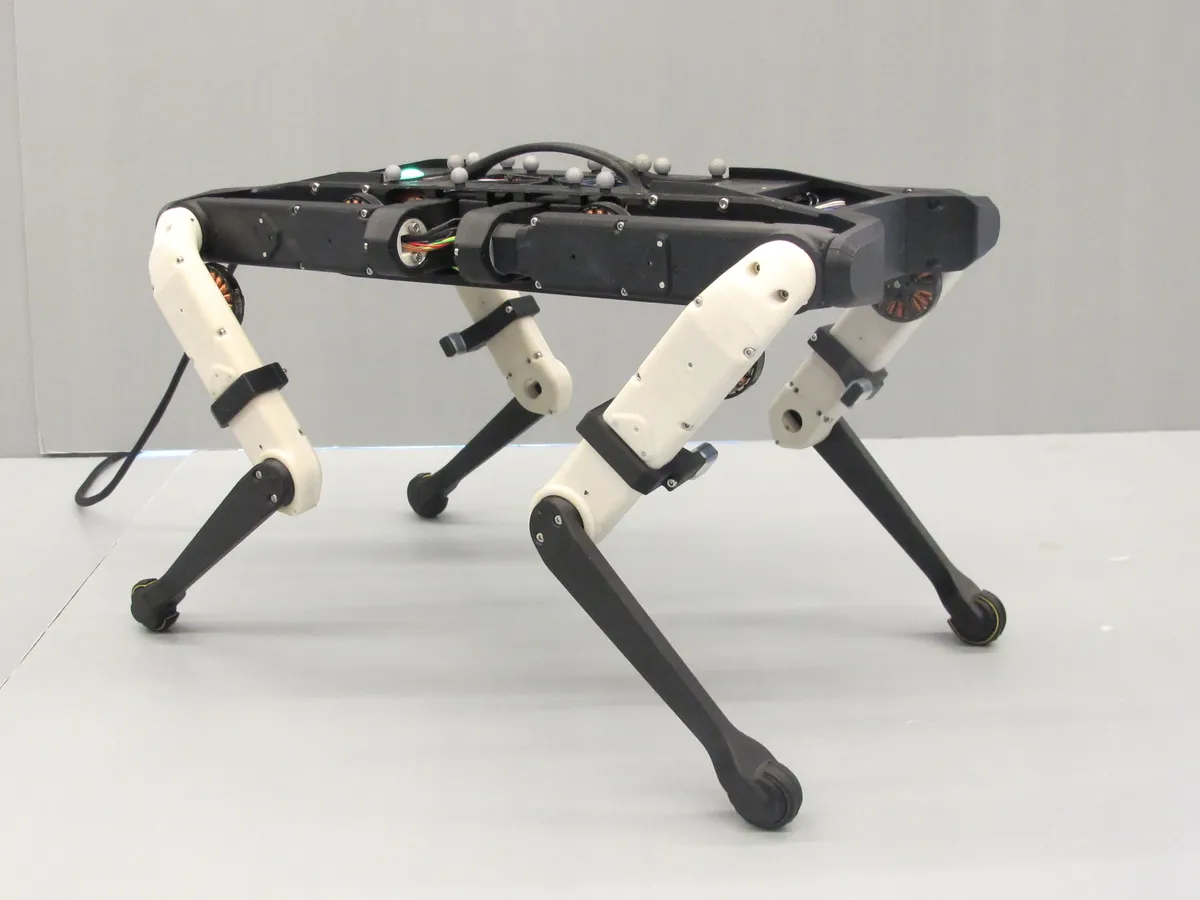
ODRI Solo-12 Torque-Controlled Quadruped Por Felix Grimminger and the Open Dynamic Robot Initiative (MPI-IS, NYU) · Proyecto de ejemplo · 7 visitas · 0 remezclas The 12-joint version of the open ODRI research quadruped, with a hip ab/adduction actuator on every leg 0GuardarRemezclarCopiar enlace Coste estimado de las piezasAún no hay precios vistosDificultadDifícilPiezas11 piezas · 211 uds. Empezar la guía de montaje →