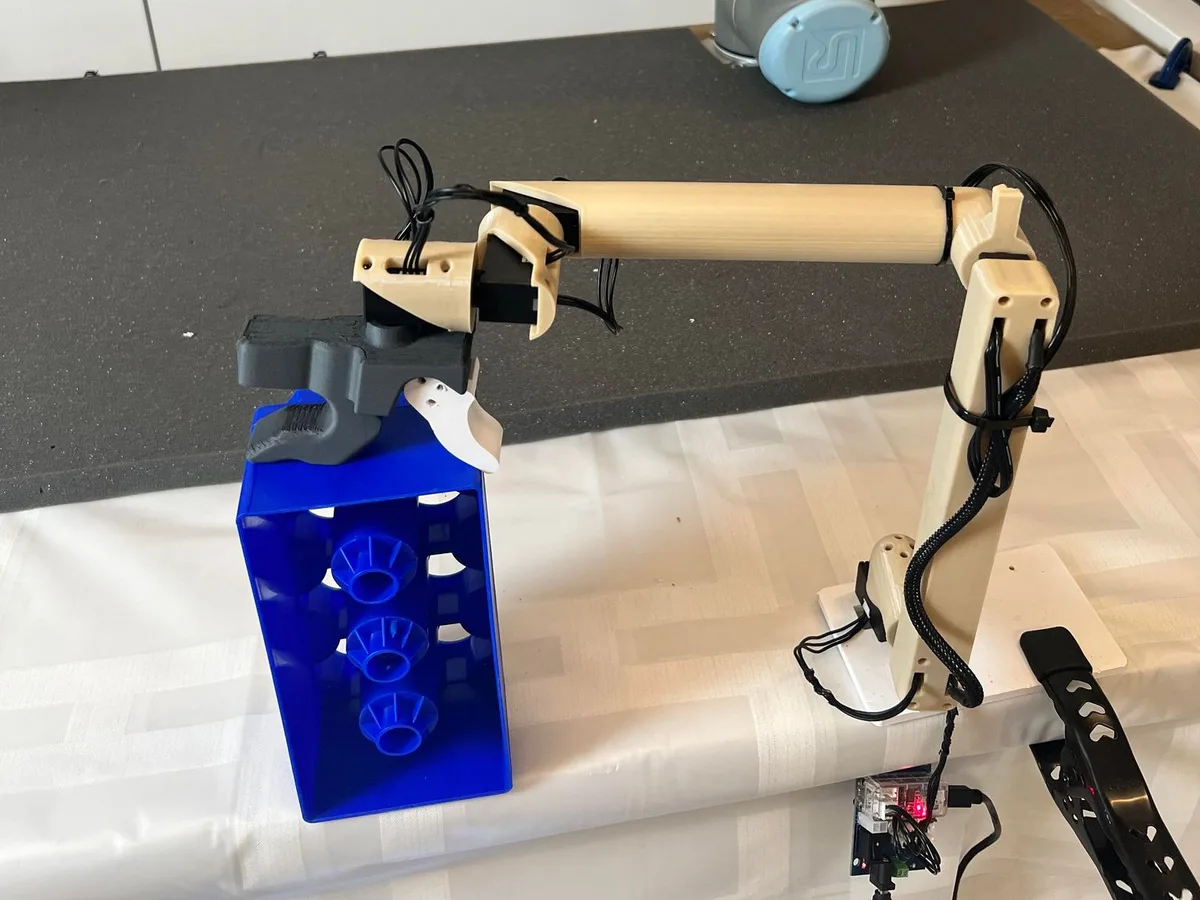
GELLO Teleoperation Controller for the UR5 Por Philipp Wu, Yide Shentu, Zhongke Yi, Xingyu Lin and Pieter Abbeel (UC Berkeley) · Proyecto de ejemplo · 7 visitas · 0 remezclas A 3D-printed copy of a UR arm with Dynamixel joints that steers the real robot by hand 0GuardarRemezclarCopiar enlace Coste estimado de las piezas DificultadModeradaPiezas4 piezas · 9 uds. Empezar la guía de montaje →