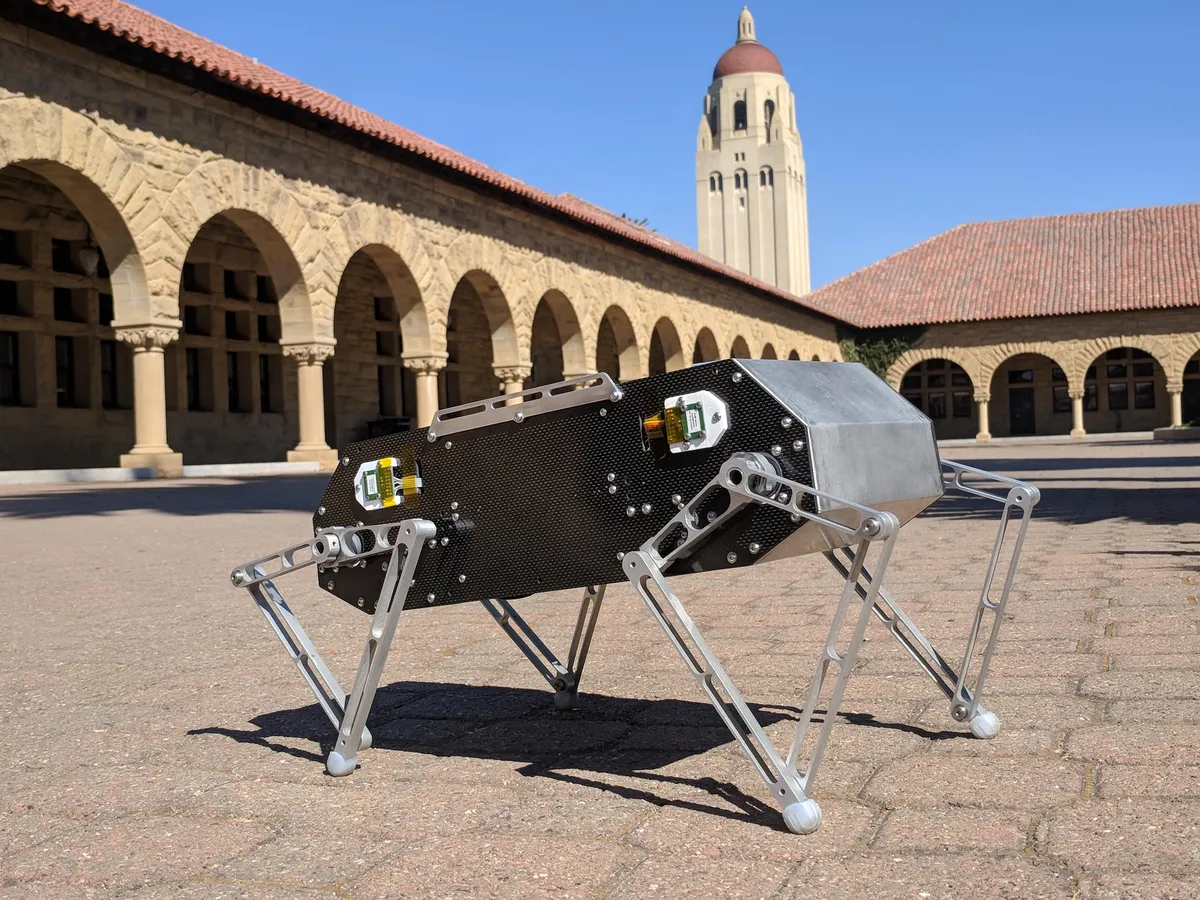
Stanford Doggo 作者:Nathan Kau and Stanford Student Robotics (Extreme Mobility team) · 示例作品 · 10 次浏览 · 0 次改作 A shoebox-sized research quadruped with ODrive-driven five-bar legs that trots, pronks, jumps and flips 0保存改作复制链接 零件费用估算还没有看到价格难度困难零件1 个零件 · 8 件 开始组装指南 →