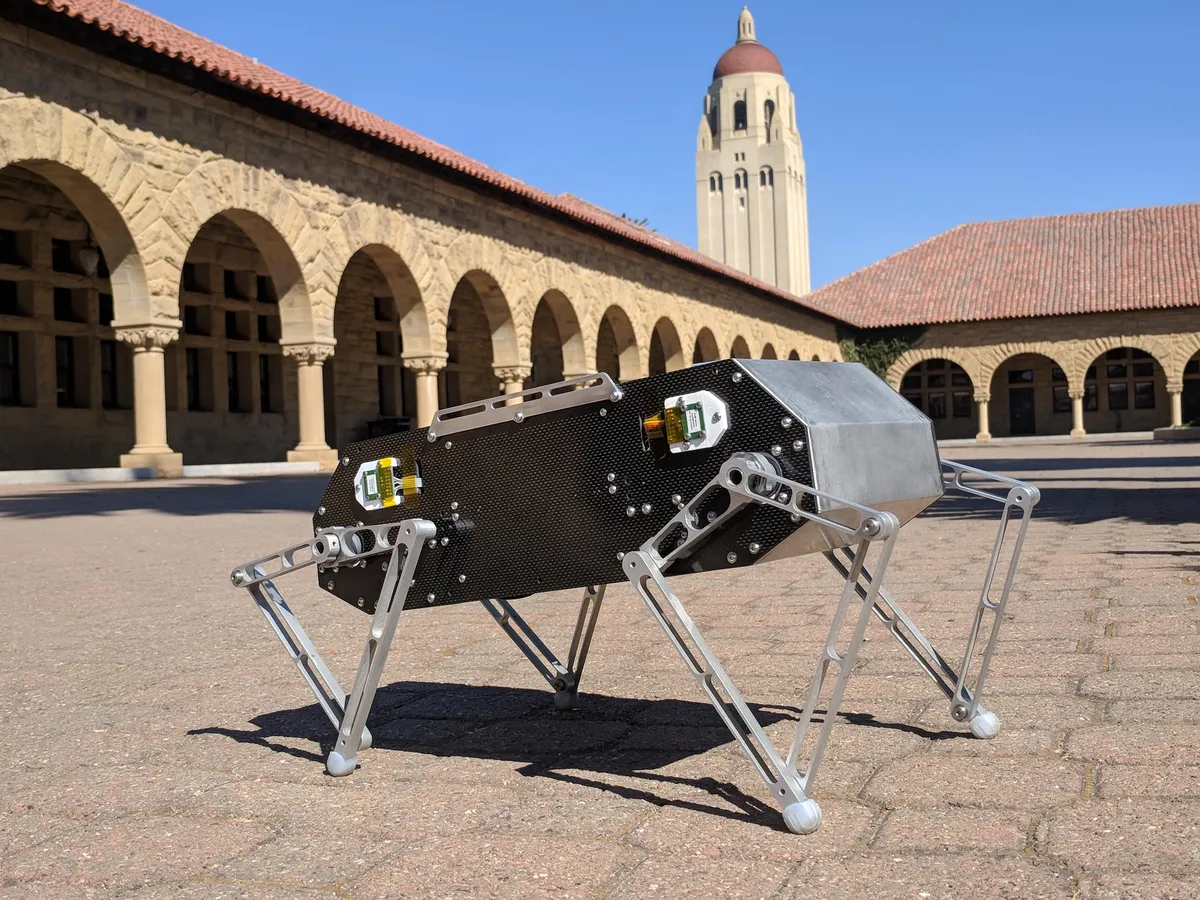
Stanford Doggo Por Nathan Kau and Stanford Student Robotics (Extreme Mobility team) · Proyecto de ejemplo · 10 visitas · 0 remezclas A shoebox-sized research quadruped with ODrive-driven five-bar legs that trots, pronks, jumps and flips 0GuardarRemezclarCopiar enlace Coste estimado de las piezasAún no hay precios vistosDificultadDifícilPiezas1 piezas · 8 uds. Empezar la guía de montaje →