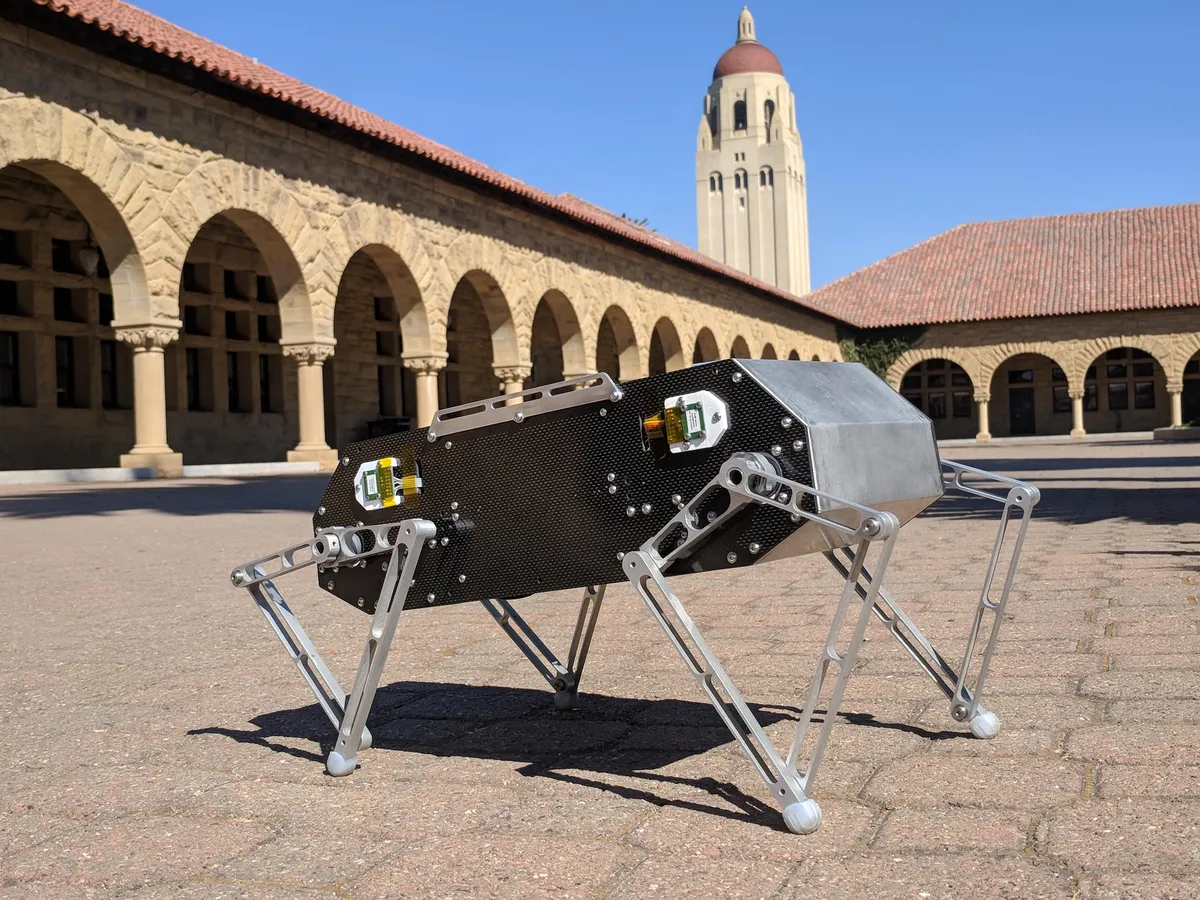
Stanford Doggo By Nathan Kau and Stanford Student Robotics (Extreme Mobility team) · Example build · 10 views · 0 remixes A shoebox-sized research quadruped with ODrive-driven five-bar legs that trots, pronks, jumps and flips 0SaveRemixCopy link Estimated parts costNo price seen yetDifficultyDifficultParts1 part · 8 pcs Start the assembly guide →