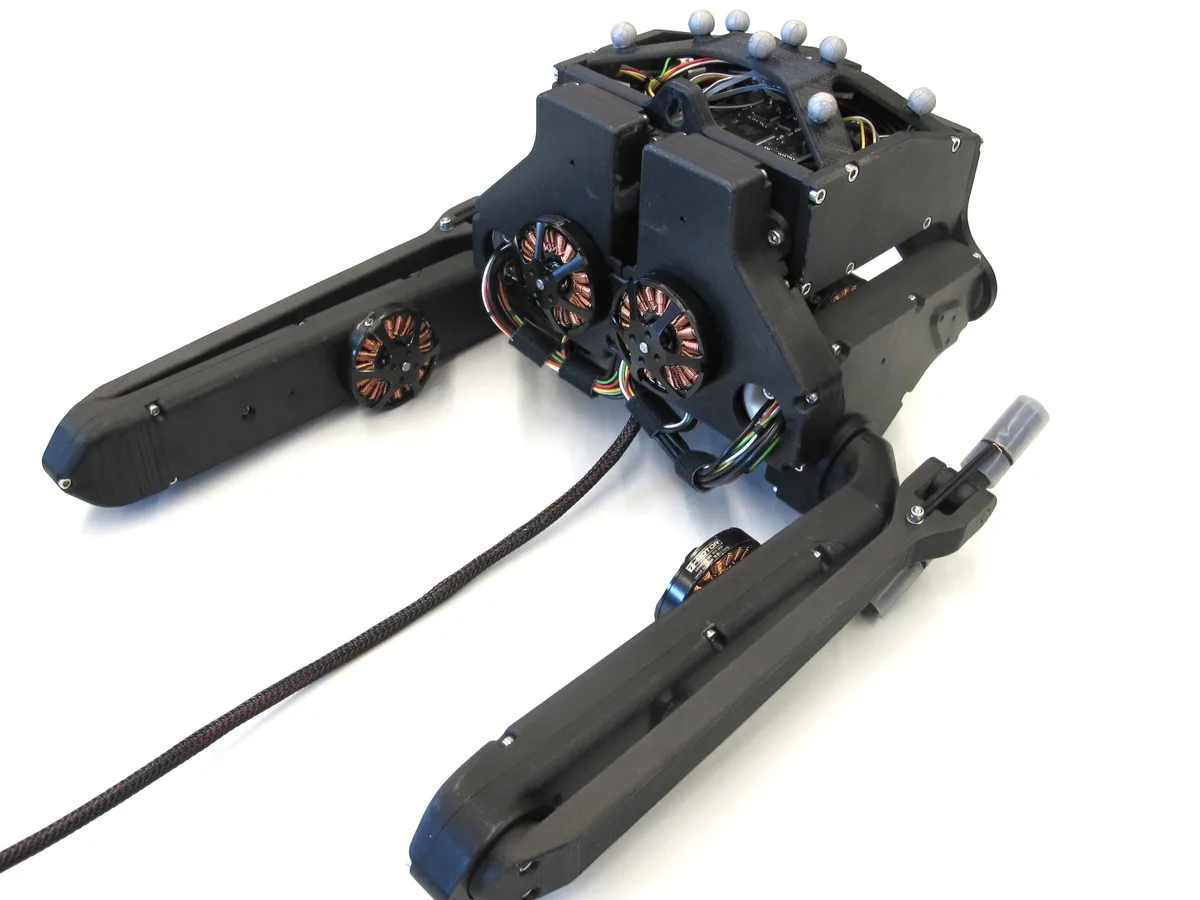
ODRI Bolt Biped Robot 作成:Open Dynamic Robot Initiative (Max Planck Society & New York University); Felix Grimminger, Jonathan Fiene, Thomas Flayols · サンプル作品 · 8 回表示 · 0 件のリミックス A tethered, torque-controlled research biped with six brushless joints and point-contact feet 0保存リミックスリンクをコピー 部品代の目安まだ価格の記録がありません難易度上級部品8 点の部品 · 54 個 組み立てガイドを始める →