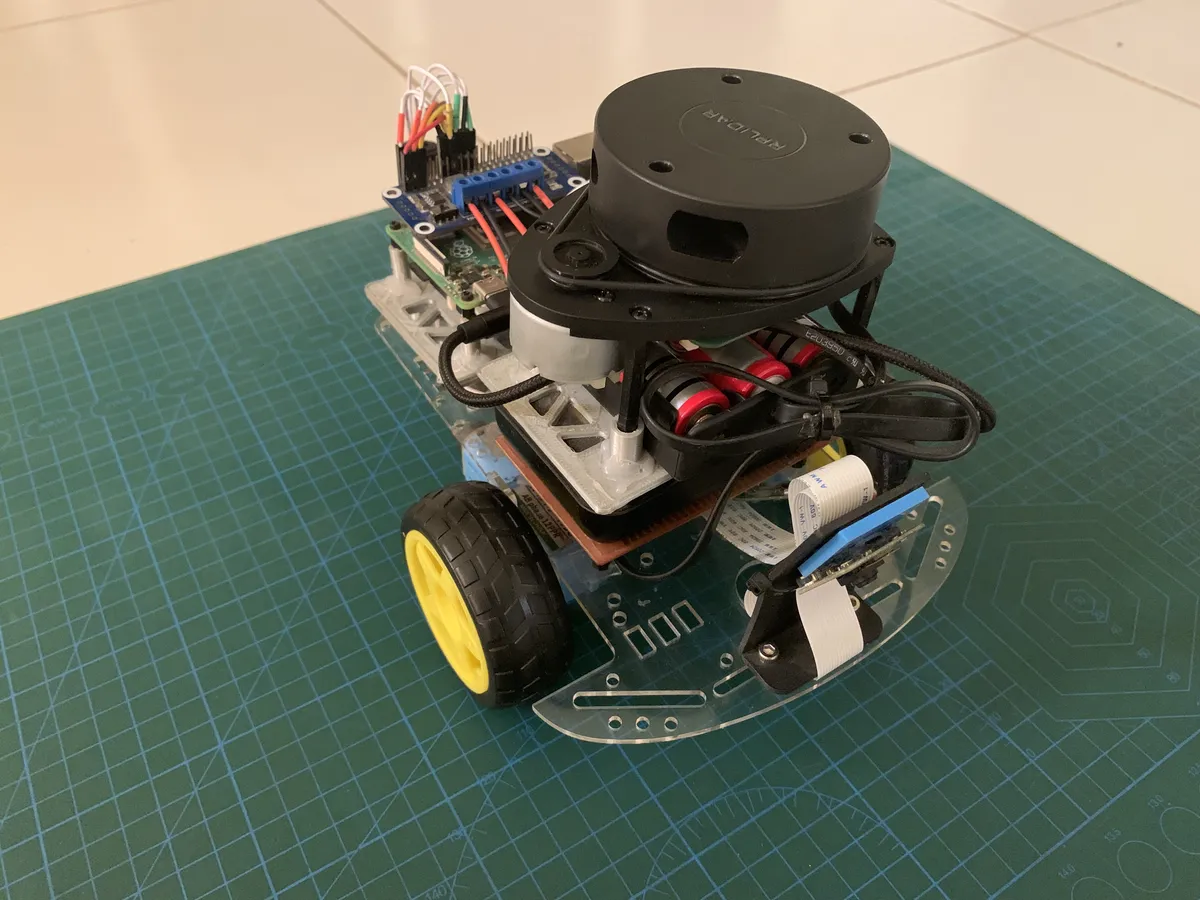
Lidarbot ROS 2 Differential-Drive Robot 作者:Chinedu Amadi (TheNoobInventor) · 範例作品 · 7 次瀏覽 · 0 次改作 A Raspberry Pi 4 robot on a two-wheel chassis that maps and navigates with an RPLIDAR A1, Nav2 and ros2_control 0儲存改作複製連結 零件費用估計 6 個零件中有 2 個有價格難度中等零件6 個零件 · 8 件 開始組裝指南 →